APSIPA ASC 2026
ATW-GS
Anisotropic transmittance windows for anti-aliased 3D Gaussian splatting
- Anti-aliasing
- Multi-scale rendering
- 3D Gaussian splatting
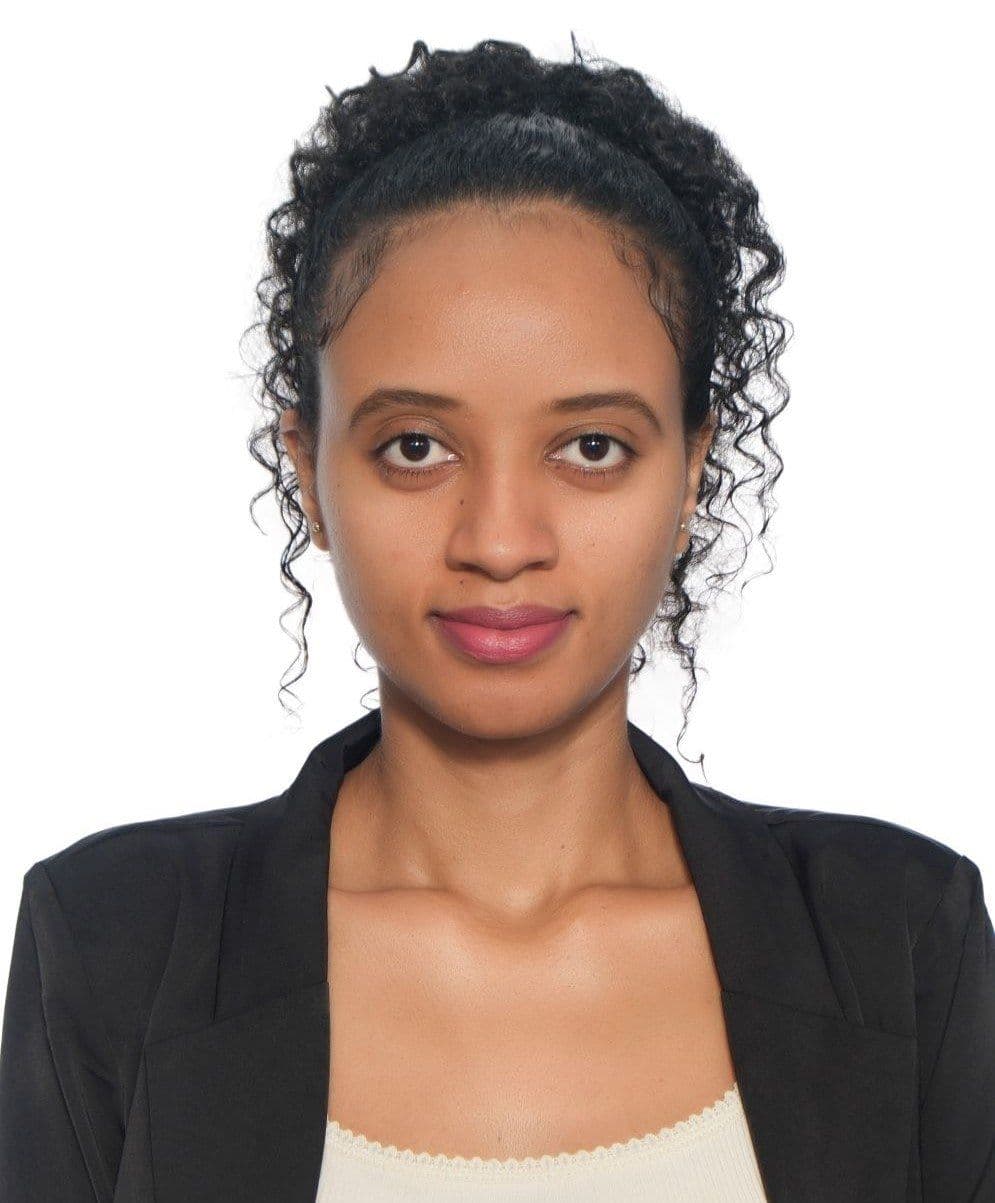
PhD Candidate · The Hong Kong Polytechnic University
Reliable AI for 3D visual perception and scene understanding
I develop methods that recover and understand three-dimensional scenes from ordinary images and video, even when the views are few, uneven, or limited by how the camera moved. My aim is AI that is accurate and efficient, and honest about how much it really knows.
Research focus
Recovering geometry and appearance from a few, unevenly distributed views, using stereo priors, targeted densification and optimization that stays stable when the data are insufficient.
Recognizing and locating objects inside reconstructed scenes, with volumetric learning that stays robust when views are sparse and noisy.
Reducing model size and training cost without losing quality, and keeping rendering stable at scales and distances outside the fitted regime.
Physics-informed learning with calibrated uncertainty for engineering prediction, and models that report where their own evidence is thin.
Selected systems
APSIPA ASC 2026
Anisotropic transmittance windows for anti-aliased 3D Gaussian splatting
Stabilizing joint optimization with weight averaging and multi-resolution supervision for egocentric 3D Gaussian splatting
Structure-aware, view-consistent densification for accelerated 3D Gaussian splatting
Publications

H. L. Goshu, T. Wakjira, M. Atlaw, K.-C. Chan, S. Lai, K.-M. Lam
Neurocomputing

T. Wakjira, H. L. Goshu
Applied Soft Computing

K.-C. Chan, J. Xiao, H. L. Goshu, K.-M. Lam
ACM MM 2024
News
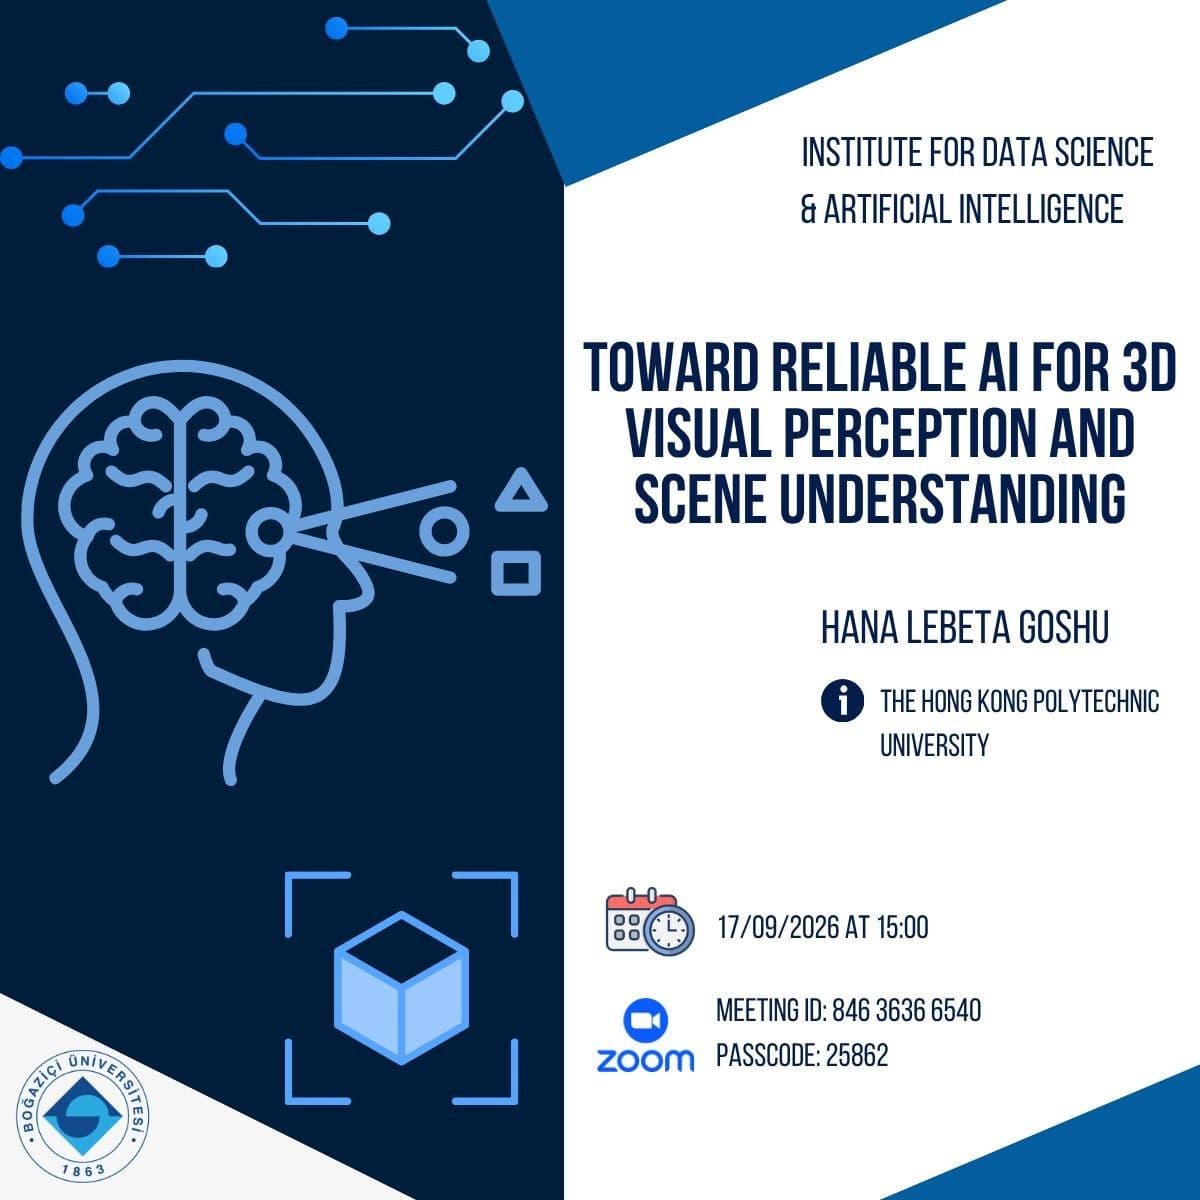
I gave an invited seminar at the Institute for Data Science and Artificial Intelligence (DSAI), Boğaziçi University, titled “Toward Reliable AI for 3D Visual Perception and Scene Understanding.”
Read moreTalks
All talksToward Reliable AI for 3D Visual Perception and Scene Understanding
Invited seminar, Institute for Data Science and Artificial Intelligence, Boğaziçi University
Feature Calibration Mechanisms for NeRF-Based 3D Object Detection
PolyU EEE Research Student Conference (PRSC 2025)
NeRF-FCM: Feature Calibration Mechanisms for NeRF-Based 3D Object Detection
APSIPA Annual Summit and Conference 2024
Teaching
Teaching6 courses at undergraduate and postgraduate level, taught in English.
Get in touch
I welcome conversations about research collaboration, invited talks and teaching in AI and computer vision.