
Journal article2026
NeRF-UAVeL: Unified Attention-Driven Volumetric Learning for Robust NeRF-Based 3D Object Detection
H. L. Goshu, T. Wakjira, M. Atlaw, K.-C. Chan, S. Lai, K.-M. Lam
Neurocomputing, vol. 702, 134610
Neurocomputing · 2026
Unified attention-driven volumetric learning for robust NeRF-based 3D object detection
Hana L. Goshu, Tadesse G. Wakjira, Meklit M. Atlaw, Kin-Chung Chan, Songjiang Lai, Kin-Man Lam
Ground truthDrag to compareNeRF-UAVeL
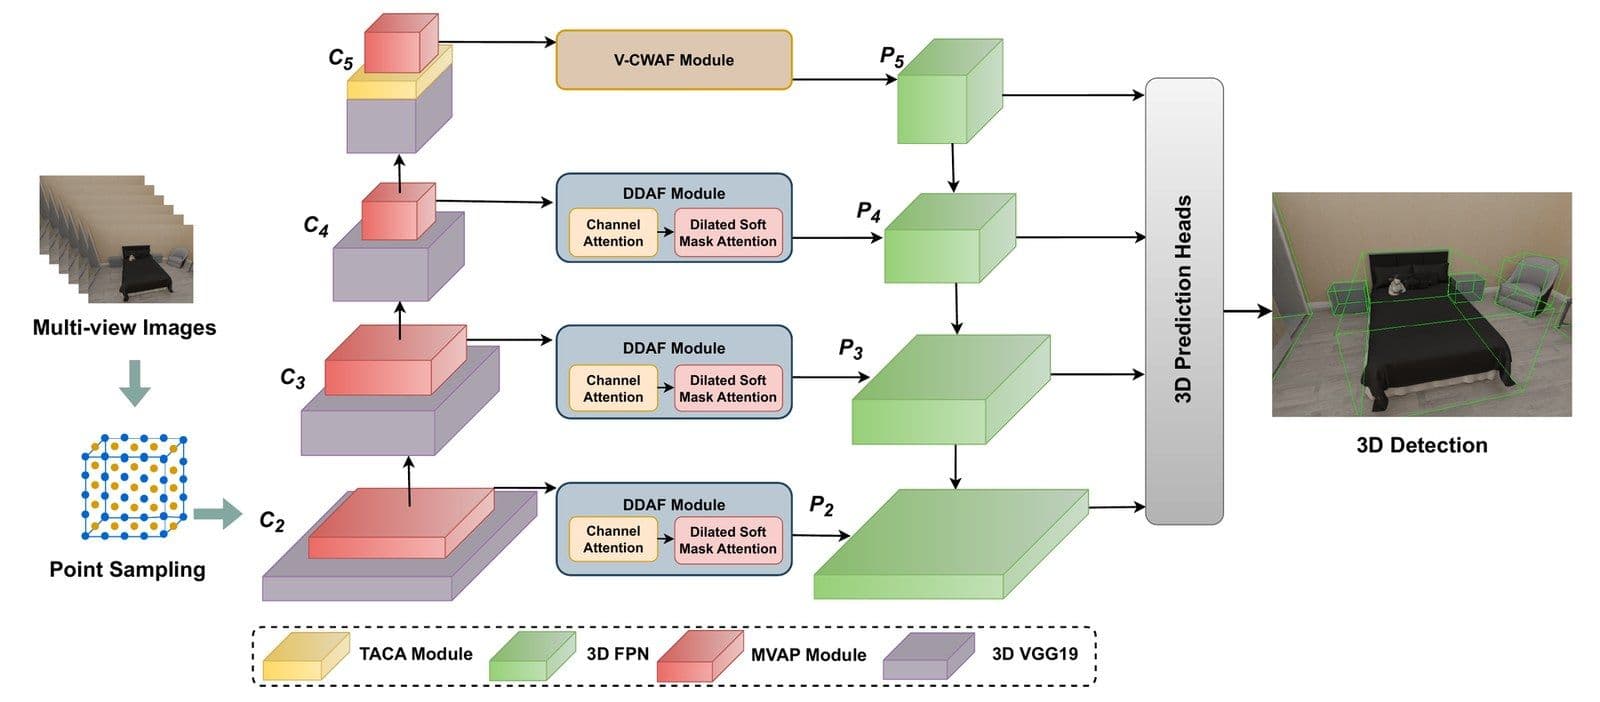
Three-dimensional (3D) object detection based on Neural Radiance Fields (NeRF) has emerged as a promising direction for reconstructing complex environments from posed RGB images. However, existing NeRF-based detectors often suffer from coarse feature encoding and limited attention to multi-scale volumetric structures, leading to inaccurate localization and poor generalization in real-world scenarios. To address these challenges, we propose NeRF-UAVeL, a unified attention-driven volumetric learning framework for 3D object detection that integrates four novel modules into a NeRF-derived 3D volumetric backbone, namely, Multi-dimensional Volumetric Attention Pooling (MVAP), Tri-Scale Asymmetric Convolutional Aggregation (TACA), Dual-Domain Attention Fusion (DDAF), and Volumetric Cross-Window Attention Fusion (V-CWAF). MVAP enhances spatial selectivity through adaptive attention-based pooling, TACA captures multi-scale volumetric features through asymmetric convolutional branches, DDAF applies channel and multi-scale spatial recalibration for refined feature emphasis, and V-CWAF applies windowed self-attention with dual-stage channel recalibration to boost high-level semantic encoding. Extensive experiments on the 3D-FRONT and ScanNet datasets demonstrate that NeRF-UAVeL outperforms both point cloud-based and multi-view-based methods. Specifically, it improves AP50 by 6.7 and R50 by 7.3 over the baseline on 3D-FRONT, and achieves a 6.9 improvement in AP50 and 2.9 in R50 on the ScanNet dataset. These results confirm the effectiveness of our attention-calibrated, multi-scale volumetric architecture in producing precise and robust 3D bounding box predictions across both synthetic and real-world scenes.
NeRF-UAVeL augments a NeRF-derived volumetric backbone with four attention-driven modules at different stages of the feature hierarchy.
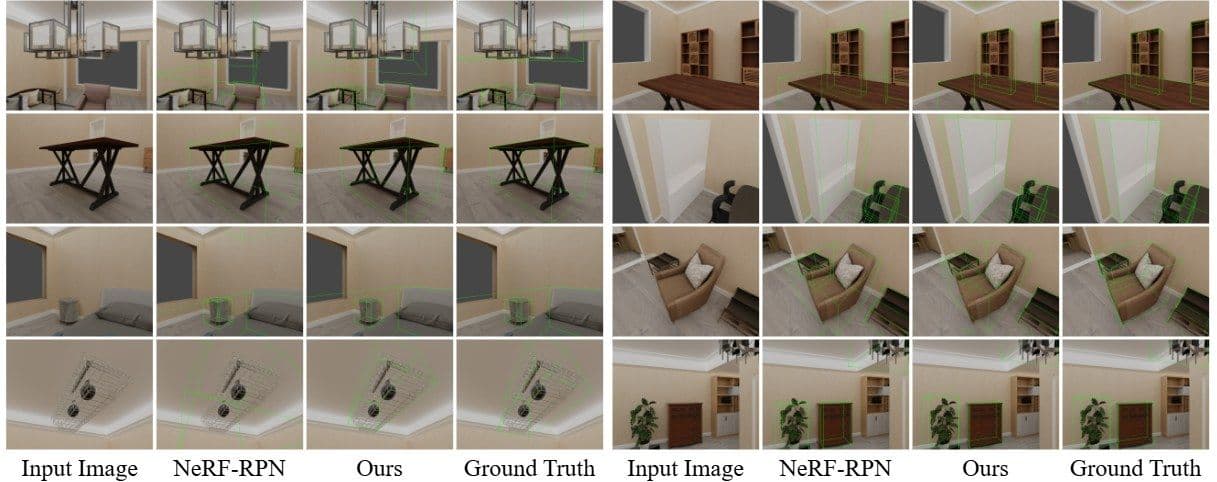
The first three methods are point cloud-based; the remaining methods detect objects from multi-view images.
| Method | 3D-FRONT R25 | R50 | AP25 | AP50 | ScanNet R25 | R50 | AP25 | AP50 |
|---|---|---|---|---|---|---|---|---|
| VoteNet | 81.5 | 61.6 | 73.0 | 49.6 | 78.5 | 34.2 | 66.8 | 18.2 |
| GroupFree | 84.9 | 63.7 | 72.1 | 45.1 | 75.2 | 37.6 | 60.1 | 20.4 |
| FCAF3D | 89.1 | 56.9 | 73.1 | 35.2 | 90.2 | 42.4 | 63.7 | 18.5 |
| ImVoxNet | 88.3 | 71.5 | 86.1 | 66.4 | 51.7 | 20.2 | 37.3 | 9.8 |
| NeRF-MAE* | 97.2 | 74.5 | 85.3 | 63.0 | 92.0 | 39.5 | 57.1 | 17.0 |
| NeRF-RPN | 96.3 | 69.9 | 85.2 | 59.9 | 89.2 | 42.9 | 55.5 | 18.4 |
| NeRF-UAVeL | 98.5 | 77.2 | 87.3 | 66.6 | 92.6 | 45.8 | 60.1 | 25.3 |
* NeRF-MAE is pretrained on 3D-FRONT and two additional datasets, Hypersim and HM3D.
@article{goshu2026nerfuavel,
  title   = {NeRF-UAVeL: Unified attention-driven volumetric learning for robust NeRF-based 3D object detection},
  author  = {Goshu, Hana L. and Wakjira, Tadesse G. and Atlaw, Meklit M. and Chan, Kin-Chung and Lai, Songjiang and Lam, Kin-Man},
  journal = {Neurocomputing},
  volume  = {702},
  pages   = {134610},
  year    = {2026},
  doi     = {10.1016/j.neucom.2026.134610}
}H. L. Goshu, T. Wakjira, M. Atlaw, K.-C. Chan, S. Lai, K.-M. Lam
Neurocomputing, vol. 702, 134610
APSIPA ASC 2026
Anisotropic transmittance windows for anti-aliased 3D Gaussian splatting
Stabilizing joint optimization with weight averaging and multi-resolution supervision for egocentric 3D Gaussian splatting
Structure-aware, view-consistent densification for accelerated 3D Gaussian splatting